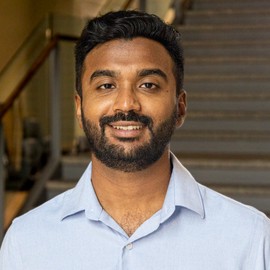
Karthik Mahadevan
Incoming Assistant Professor
I am an incoming Assistant Professor in the Department of Computer Science at UT Austin starting Spring 2027, where I will direct the ENACT Lab.
My research interests lie in how we can facilitate interactions between humans and robots. I am wrapping up my Postdoctoral research at MIT, and previously completed my PhD in Computer Science at the University of Toronto.
My PhD research was supported by the NSERC CGS-D Fellowship and the Google PhD Fellowship. My work is regularly published at top-tier HRI and HCI venues including HRI, CHI, and UIST, where I have received 2 best paper awards and 1 honorable mention award. I have also spent time in industry research labs including at Google DeepMind, Meta Reality Labs, Autodesk Research, and Honda Research Institute.