Abstract
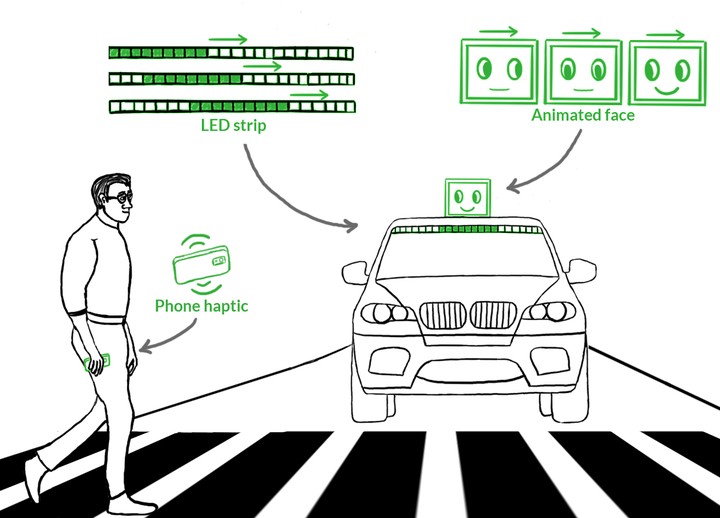
AV-pedestrian interaction will impact pedestrian safety, etiquette, and overall acceptance of AV technology. Evaluating AV-pedestrian interaction is challenging given limited availability of AVs and safety concerns. These challenges are compounded by “mixed traffic” conditions:colon studying AV-pedestrian interaction will be difficult in traffic consisting of vehicles varying in autonomy level. We propose immersive pedestrian simulators as design tools to study AV-pedestrian interaction, allowing rapid prototyping and evaluation of future AV-pedestrian interfaces. We present OnFoot:colon a VR-based simulator that immerses participants in mixed traffic conditions and allows examination of their behavior while controlling vehicles’ autonomy-level, traffic and street characteristics, behavior of other virtual pedestrians, and integration of novel AV-pedestrian interfaces. We validated OnFoot against prior simulators and Wizard-of-Oz studies, and conducted a user study, manipulating vehicles’ autonomy level, interfaces, and pedestrian group behavior. Our findings highlight the potential to use VR simulators as powerful tools for AV-pedestrian interaction design in mixed traffic.
Karthik Mahadevan
Incoming Assistant Professor
I study human-robot interaction, building systems that help people and robots understand each other.